Home
Experience
Blog
Projects
Talks
Publications
Contact
Light
Dark
Automatic
Publications
Type
Journal article
Conference paper
Thesis
Date
2026
2025
2024
2023
2022
2021
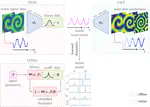
VENI, VINDy, VICI: A generative reduced-order modeling framework with uncertainty quantification
Generative models are transforming science and engineering by enabling efficient synthetization and exploration of new scenarios for …
Paolo Conti
,
Jonas Kneifl
,
Andrea Manzoni
,
Attilio Frangi
,
Jörg Fehr
,
Steven L. Brunton
,
J. Nathan Kutz
Cite
Code
Project
DOI
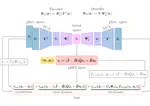
Data-driven identification of latent port-Hamiltonian systems
Conventional physics-based modeling techniques involve high effort, e.g., time and expert knowledge, while data-driven methods often …
Johannes Rettberg
,
Jonas Kneifl
,
Julius Herb
,
Patrick Buchfink
,
Jörg Fehr
,
Bernard Haasdonk
Cite
Code
Project
DOI
Data-driven Surrogate Modeling of Structural Dynamical Systems via Latent Space Representations
Numerical simulations provide powerful predictive capabilities to analyze the dynamic behavior of complex systems but suffer from high …
Jonas Kneifl
Cite
Project
DOI
Multi-Fidelity Surrogate Model for Representing Hierarchical and Conflicting Databases to Approximate Human-Seat Interaction
Gia Huy Mike Huynh
,
Niklas Fahse
,
Jonas Kneifl
,
Joachim Linn
,
Jörg Fehr
Cite
Project
DOI
Accelerated Non‐linear Stability Analysis Based on Predictions From Data‐Based Surrogate Models
Anika Strauß
,
Jonas Kneifl
,
Anton Tkachuk
,
Jörg Fehr
,
Manfred Bischoff
Cite
Project
DOI
Multi-hierarchical surrogate learning for explicit structural dynamical systems using graph convolutional neural networks
Highly nonlinear dynamic finite element simulations using explicit time integration are particularly valuable tools for structural …
Jonas Kneifl
,
Jörg Fehr
,
Steven L. Brunton
,
J. Nathan Kutz
Cite
Code
Project
DOI
On using machine learning algorithms for motorcycle collision detection
Globally, motorcycles attract vast and varied users. However, since the rate of severe injury and fatality in motorcycle accidents far …
Philipp Rodegast
,
Steffen Maier
,
Jonas Kneifl
,
Jörg Fehr
Cite
Project
DOI
Low-dimensional data-based surrogate model of a continuum-mechanical musculoskeletal system based on non-intrusive model order reduction
Over the last decades, computer modeling has evolved from a supporting tool for engineering prototype design to an ubiquitous …
Jonas Kneifl
,
David Rosin
,
Okan Avci
,
Oliver Röhrle
,
Jörg Fehr
Cite
Project
DOI
Real-time Human Response Prediction Using a Non-intrusive Data-driven Model Reduction Scheme
Recent research in non-intrusive data-driven model order reduction (MOR) enabled accurate and efficient approximation of parameterized …
Jonas Kneifl
,
J. Hay
,
Jörg Fehr
Cite
Project
DOI
Physics-informed Neural Networks-based Model Predictive Control for Multi-link Manipulators
We discuss nonlinear model predictive control (MPC) for multi-body dynamics via physics-informed machine learning methods. In more …
Jonas Nicodemus
,
Jonas Kneifl
,
Jörg Fehr
,
Benjamin Unger
Cite
Project
DOI
A nonintrusive nonlinear model reduction method for structural dynamical problems based on machine learning
Abstract Model order reduction (MOR) has become one of the most widely used tools to create efficient surrogate models for …
Jonas Kneifl
,
Dennis Grunert
,
Jörg Fehr
Cite
Project
DOI
Machine Learning Algorithms for Learning Nonlinear Terms of Reduced Mechanical Models in Explicit Structural Dynamics
Modeling and simulations are a pillar in the development of complex technical systems. However, for time-critical applications a …
Jonas Kneifl
,
Jörg Fehr
Cite
Project
DOI
Cite
×